Geometric control
Lie groups, symmetry, and optimal control as tools for understanding and designing motion.
Postdoctoral Scholar · University of South Florida
Geometry, motion, and the control of robotic systems.
I study how geometry can help us understand and control movement, from coordinated groups of agents to robots that interact with people.
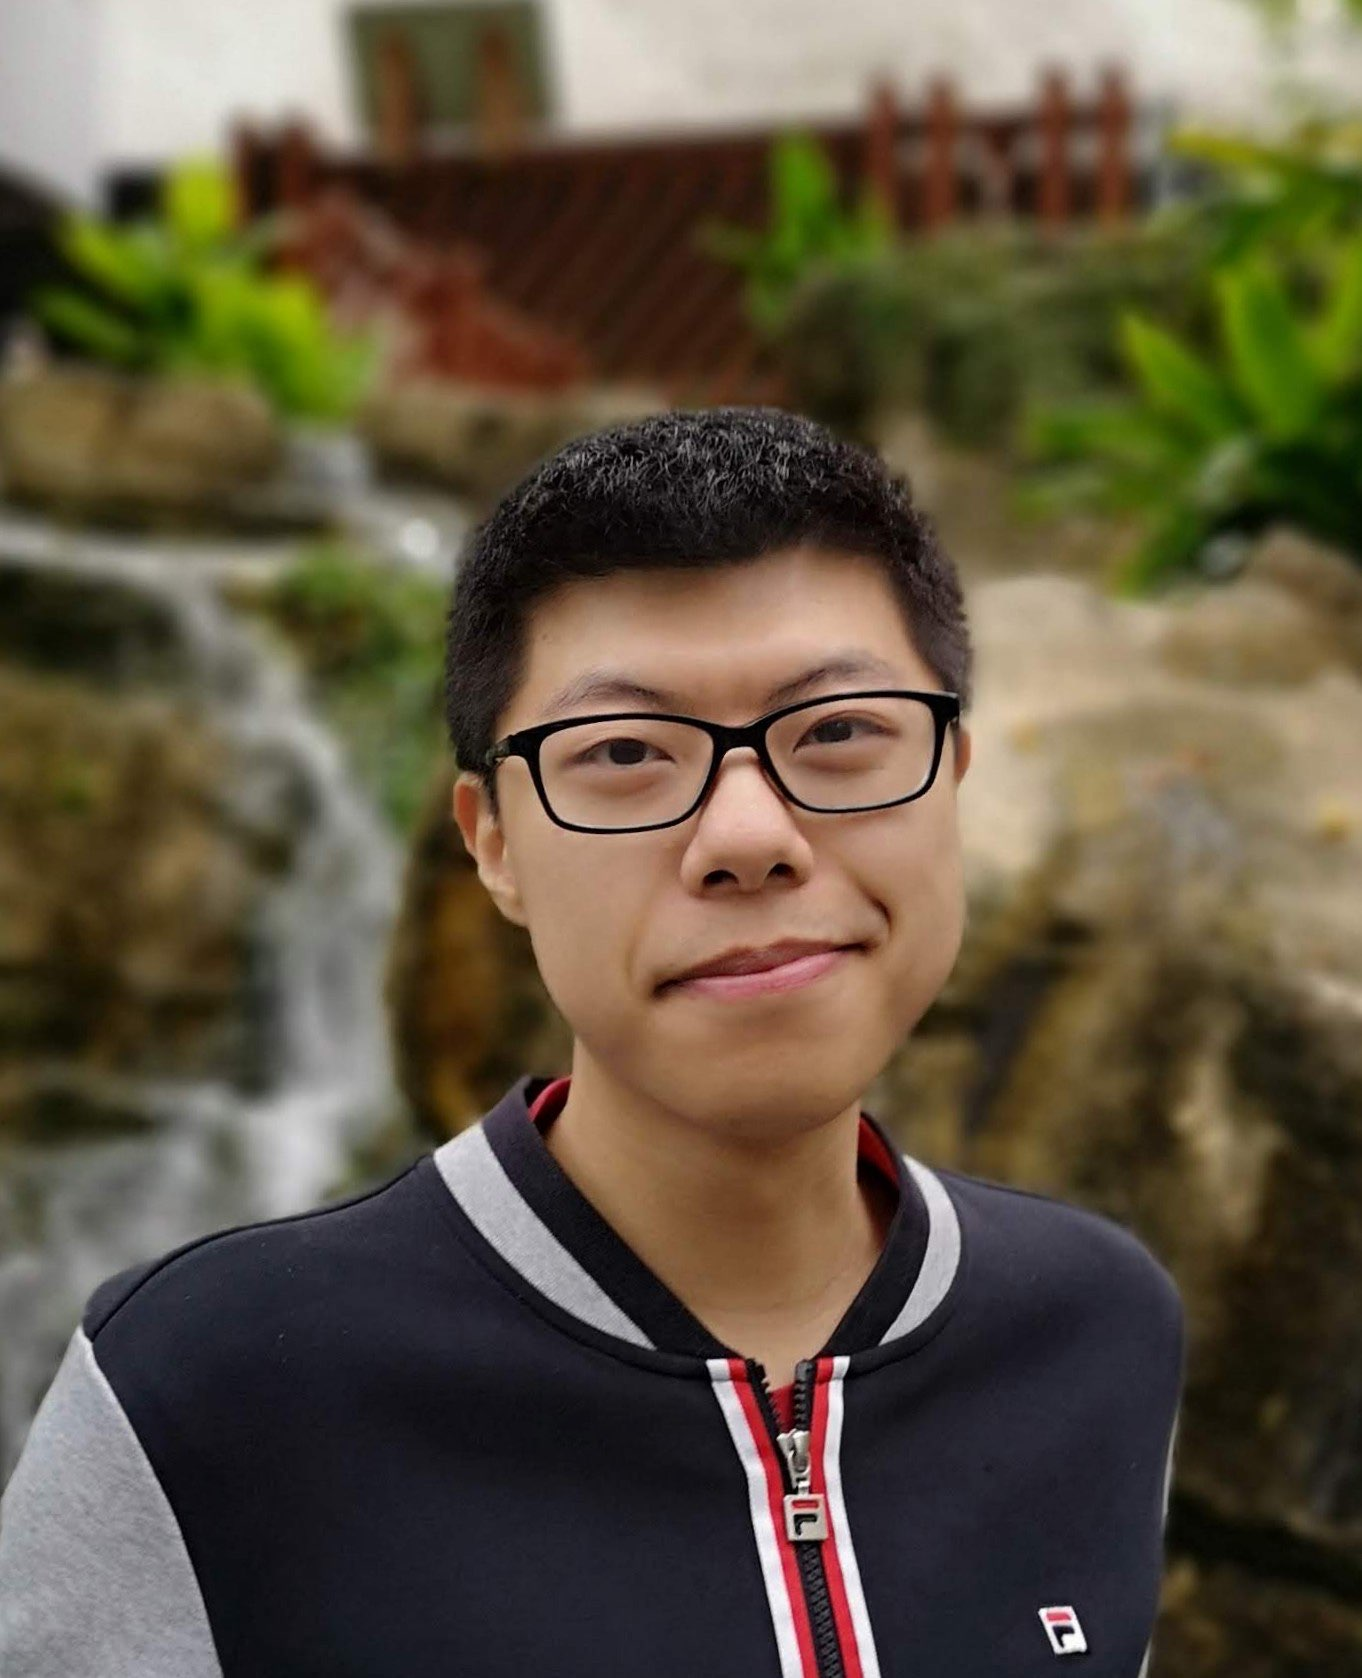
A little background
I am a Postdoctoral Scholar at the University of South Florida, working with Professor Udit Halder. My research connects geometric control, motion planning, and human–robot interaction, with recent work on collective motion and soft robotic grasping.
I received my Ph.D. in Electrical Engineering from the University of Maryland, College Park in 2025, advised by Professor P. S. Krishnaprasad. My dissertation developed geometric models of human movement and control methods for interacting agents using Lie groups and equi-affine geometry.
Research groupQuestions that drive my work
Understanding movement.
Designing interaction.
Lie groups, symmetry, and optimal control as tools for understanding and designing motion.
Feedback control and leader–follower coordination in multi-agent systems.
Equi-affine models of human motion and geometry-based approaches to soft robotic grasping.
Current directions
I am developing state-estimation methods for leader–follower systems in which the follower does not have access to the leader’s instantaneous control. Using onboard relative measurements such as range and bearing, this work studies how unmeasured geometric states can be reconstructed and used for feedback control under limited sensing.
I am exploring how neural networks can accelerate optimal control problems with known geometric structure. Rather than predicting an entire trajectory, the network predicts a small number of reduced quantities—such as initial costates or invariant parameters—from which the optimal motion can be generated through the underlying Lie–Poisson dynamics.
I am extending geometry-based continuum grasping from planar objects to three-dimensional surfaces. The goal is to understand whether the geometry of an object can intrinsically define surface curves that maximize grasp quality for a prescribed arm length, recovering intuitive structures such as great circles on spheres and helical wraps around cylinders.
Papers & dissertation
Preprint · Under review
Submitted to IEEE International Conference on Robotics and Automation (ICRA); review pending
An online estimator reconstructing unobserved relative states from partial sensory measurements and known self-motion, with moving-horizon optimization and robotic pursuit experiments.
@misc{liu2026bioinspired,
  title={A bioinspired internal model-based online estimator for planar pursuit},
  author={Liu, Tengyue and Li, Xincheng and Morales Ferreira, Sofia and Galloway, Kevin and Halder, Udit},
  year={2026},
  eprint={2609.25470},
  archivePrefix={arXiv},
  primaryClass={cs.RO},
  note={Submitted to IEEE ICRA; under review},
  url={https://arxiv.org/abs/2609.25470}
}
Journal article
IEEE Control Systems Letters
Speed regulation for leader–follower formations, with stability analysis and mobile-robot experiments.
@article{li2026feedback,
  title={On Feedback Speed Control for a Planar Tracking},
  author={Li, Xincheng and Liu, Tengyue and Halder, Udit},
  journal={IEEE Control Systems Letters},
  year={2026},
  doi={10.1109/LCSYS.2026.3708578}
}
Accepted conference paper
IEEE Conference on Decision and Control (CDC), accepted
A geometric framework for shaping a soft continuum arm around an object and assessing grasp quality.
@misc{halder2026kinematics,
  title={Kinematics of continuum planar grasping},
  author={Halder, Udit and Echeverria Zambrano, Nicolas and Li, Xincheng},
  year={2026},
  eprint={2604.09800},
  archivePrefix={arXiv},
  primaryClass={cs.RO},
  note={Accepted at IEEE CDC 2026},
  url={https://arxiv.org/abs/2604.09800}
}
Doctoral dissertation
University of Maryland, College Park
Equi-affine geometry and optimal control for modeling human movement and coordinating interacting agents.
@phdthesis{li2025symmetry,
  title={Symmetry and Motion: Geometric Control of Human Agents},
  author={Li, Xincheng},
  school={University of Maryland, College Park},
  year={2025},
  doi={10.13016/rglm-vbqv}
}
Theory into practice
Research software
Code for feedback speed control in leader–follower tracking, accompanying my work on planar formation control.
Explore the codeSoftware
A compact PyTorch experiment that makes the reverse diffusion process visible through a two-dimensional line-generation task.
Explore the codeEducational software
Interactive MATLAB Live Script modules and animations introducing moving frames and natural Frenet frames for robotics, developed during my 2022 MathWorks internship.
Explore the moduleExperience & education
Academic background, selected work, and research experience.
Get in touch
For research conversations and collaboration, please reach out.
xincheng@usf.edu